Home Blog Page 312

Today in History – 17 May

0
today in history 17 may

today in history 17 may

1498

Admiral Dom Vasco-da-Gama (c.1469-1524)-I, Portuguese navigator, arrived in India. He sailed around the Cape of Good Hope to Calicut, Kerala with three vessels and was the first Westerner to sail to India from Europe. (17 or 20).

1498

Admiral Dom Vasco-da-Gama (c.1469-1524)-I, Count of Vidigueira, met the Jamerin of Calicut after arriving in India three days ago at Malabar Coast. He was joined by an experienced Gujarati pilot at Malindi. He was the 6th Governor and 2nd Viceroy of India. (17 or 22).

1540

Sher Shah defeated Humayun for the second time at Hardoi in U.P. in the battle of Kanauj.

1775

Marathas were badly mauled in the battle of Arras by Col. Keating in the first Anglo – Maratha war.

1857

Bahadhur Shah II declared as the emperor of India.

1865

Raobahadur Govind Sakharam Sardesai `Riyasatkar’ was born.

1873

Hindi daily ‘Bharat Mitra’ started from Calcutta.

1887

Ranglal Bandopadhyay, Bengali poet, essay-writer and journalist, passed away.

1949

India decided with only one dissent vote to remain within the Commonwealth of Nations.

1954

In a major civil rights victory, the U.S. Supreme Court handed down an unanimous decision in Brown v. Board of Education of Topeka, ruling that racial segregation in public educational facilities was unconstitutional. The historic decision, which brought an end to federal tolerance of racial segregation, specifically dealt with Linda Brown, a young African American girl who had been denied admission to her local elementary school in Topeka, Kansas, because of the color of her skin.

1957

Nehru, who went to Ceylon to celebrate the 2,500th anniversary of the founding of Buddhism, called for an end to nuclear tests.

1976

4 Indians successfully skied down from the slope of Trishul peak.

1980

V. S. Kumar Anandan set record of balancing on one foot for continuous 33 hrs.

1993

Visiting Israeli Foreign Minister Shimon Peres signed an MOU with his Indian counterpart to end nearly 4 decades of inactivity in bilateral relation.

1995

Three North Eastern States removes restricted area permits (RAP).

1996

Four members (Sange Sherpa, Hira Ram, Tashi Ram, Nadre Sherpa) of the Indo-Tibetan Border Police expedition climbed Mount Everest from the Chinese side.

1998

US President Bill Clinton wanted India and Pakistan to sign CTBT.

2000

The Union Cabinet cleared a proposal for setting up a new appellate tribunal for foreign exchange following the withdrawal of the FERA and the enactment of FEMA in its place.

Related Articles:

Today in History – 16 May

Today in History – 15 May

Today in History – 14 May

Today in History – 13 May

Lagrangian Mechanics: A New Perspective on Motion

0
Lagrangian Mechanics

Table of Contents

  1. Introduction
  2. Why Go Beyond Newton?
  3. Generalized Coordinates
  4. Principle of Least Action
  5. The Lagrangian Function
  6. Euler-Lagrange Equation
  7. Simple Example: Free Particle
  8. Simple Harmonic Oscillator in Lagrangian Formalism
  9. Atwood Machine via Lagrangian
  10. Constraints and Degrees of Freedom
  11. Advantages of the Lagrangian Approach
  12. Connection to Quantum Mechanics
  13. Conclusion

1. Introduction

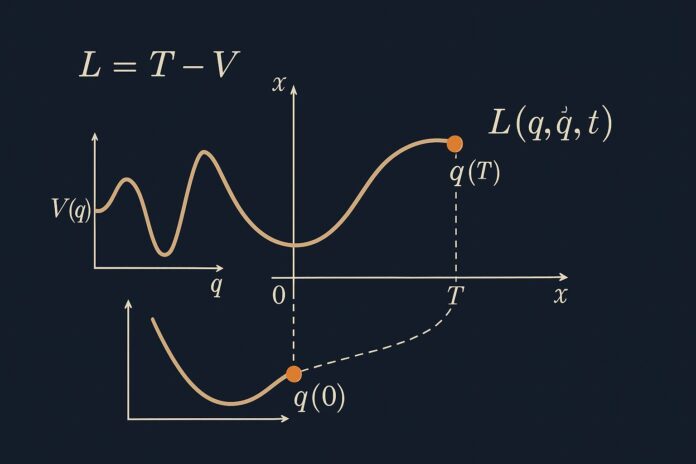
Lagrangian mechanics is an elegant and powerful reformulation of classical mechanics. Instead of focusing directly on forces (as Newtonian mechanics does), it builds from energy principles to describe the motion of systems. At its core is the idea that systems evolve in a way that minimizes (or extremizes) a quantity called action.

While Newtonโ€™s approach is intuitive and practical for many problems, the Lagrangian formulation excels in systems with constraints, symmetry, and complex interactions โ€” making it invaluable for theoretical physics and quantum mechanics.


2. Why Go Beyond Newton?

Newtonโ€™s laws work well for many problems โ€” pushing blocks, falling objects, or planetary motion. But when dealing with:

  • Multiple degrees of freedom
  • Non-Cartesian coordinates
  • Complicated constraints
  • Systems with symmetries (e.g., rotational)

Newtonโ€™s method becomes cumbersome. Lagrangian mechanics handles such cases more naturally by focusing on scalar quantities (energy) and minimizing action rather than computing forces directly.


3. Generalized Coordinates

In Lagrangian mechanics, we use generalized coordinates:

  • Denoted by \( q_1, q_2, โ€ฆ, q_n \)
  • Can be angles, distances, or any parameters describing the configuration of the system
  • Useful in non-Cartesian systems like pendulums, rotating bodies, or spherical systems

Instead of dealing with vectors \( \vec{F} \), we describe the configuration of a system in terms of coordinates and velocities \( \dot{q}_i \).


4. Principle of Least Action

The foundation of Lagrangian mechanics is the Principle of Least Action.

It states:

A physical system evolves between two configurations such that the action integral is minimized (or extremized).

The action is defined as:

\[
S = \int_{t_1}^{t_2} L(q_i, \dot{q}_i, t) \, dt
\]

Where:

  • \( L \) is the Lagrangian of the system
  • \( q_i \) and \( \dot{q}_i \) are generalized coordinates and their velocities

This principle is powerful because it leads to equations of motion without invoking force vectors directly.


5. The Lagrangian Function

The Lagrangian is a function defined as:

\[
L = T – U
\]

Where:

  • \( T \): kinetic energy
  • \( U \): potential energy

It captures the dynamics of the system through energy differences, rather than forces.

Think of the Lagrangian as a measure of how much “freedom” the system has to move, given its energy configuration.


6. Euler-Lagrange Equation

The condition for minimizing the action leads to the Euler-Lagrange equations:

\[
\frac{d}{dt} \left( \frac{\partial L}{\partial \dot{q}_i} \right) – \frac{\partial L}{\partial q_i} = 0
\]

This is the core equation of motion in Lagrangian mechanics. It replaces \( F = ma \) with a more general and coordinate-independent formulation.

You derive one Euler-Lagrange equation for each generalized coordinate \( q_i \).


7. Simple Example: Free Particle

Letโ€™s apply the Euler-Lagrange equation to a free particle (no potential energy):

  • Kinetic energy: \( T = \frac{1}{2}m\dot{x}^2 \)
  • Potential energy: \( U = 0 \)

So, the Lagrangian is:

\[
L = \frac{1}{2}m\dot{x}^2
\]

Using Euler-Lagrange:

\[
\frac{d}{dt} \left( m\dot{x} \right) = 0 \quad \Rightarrow \quad m\ddot{x} = 0
\]

This confirms Newtonโ€™s first law: a free particle moves at constant velocity.


8. SHO in Lagrangian Formalism

Letโ€™s re-derive the simple harmonic oscillator (spring system) using Lagrangian mechanics.

  • \( T = \frac{1}{2}m\dot{x}^2 \)
  • \( U = \frac{1}{2}kx^2 \)

\[
L = \frac{1}{2}m\dot{x}^2 – \frac{1}{2}kx^2
\]

Now apply the Euler-Lagrange equation:

\[
\frac{d}{dt}(m\dot{x}) + kx = 0 \Rightarrow m\ddot{x} + kx = 0
\]

This reproduces the SHO differential equation โ€” but without invoking any forces explicitly.


9. Atwood Machine via Lagrangian

Consider an Atwood machine: two masses \( m_1 \) and \( m_2 \) connected by a string over a pulley.

Let \( x \) be the displacement of \( m_1 \) downward (so \( m_2 \) moves up by the same amount).

  • \( T = \frac{1}{2}m_1 \dot{x}^2 + \frac{1}{2}m_2 \dot{x}^2 = \frac{1}{2}(m_1 + m_2)\dot{x}^2 \)
  • \( U = -m_1gx + m_2g x = (m_2 – m_1)gx \)

Lagrangian:

\[
L = \frac{1}{2}(m_1 + m_2)\dot{x}^2 – (m_2 – m_1)gx
\]

Apply Euler-Lagrange:

\[
(m_1 + m_2)\ddot{x} = (m_2 – m_1)g
\]

Which matches the standard result obtained via Newtonโ€™s laws โ€” but more elegantly.


10. Constraints and Degrees of Freedom

A major strength of the Lagrangian approach is its treatment of constraints.

  • Constraints restrict motion (e.g., a pendulum is constrained to swing along an arc).
  • Rather than using forces of constraint (like tension), Lagrangian mechanics handles them by reducing the number of coordinates.

The number of degrees of freedom equals the number of independent generalized coordinates after accounting for constraints.


11. Advantages of the Lagrangian Approach

  • Coordinate-independence: Works in polar, spherical, or any coordinates.
  • Scales well: Easily applies to multi-body systems.
  • Energy-based: Uses scalar quantities (simpler math).
  • Elegant with symmetries: Symmetries lead to conservation laws (via Noetherโ€™s theorem).
  • Foundation for quantum mechanics and field theory.

12. Connection to Quantum Mechanics

Lagrangian mechanics leads directly into quantum physics via Feynman’s path integral formulation, where the probability of a particleโ€™s path is weighted by:

\[
e^{iS/\hbar}
\]

The action \( S \) is the same as in classical mechanics:

\[
S = \int L \, dt
\]

In this view, all paths are possible, but the classical path is the one where the action is extremized โ€” precisely the Principle of Least Action.


13. Conclusion

Lagrangian mechanics reimagines motion as an optimization problem, replacing Newtonโ€™s vector-based force laws with elegant energy principles. Itโ€™s especially powerful in dealing with complex systems, constraints, and arbitrary coordinates โ€” and provides the conceptual bridge from classical physics to quantum mechanics.

For learners, mastering this framework not only simplifies many physical problems but also prepares the ground for understanding advanced physics โ€” from quantum field theory to general relativity.


.

Today in History – 16 May

0
today in history 16 may

today in history 16 may

1911

Pumping Station of Calcutta was commissioned at Tallah.

1929

On this day in 1929, the Academy of Motion Picture Arts and Sciences handed out its first awards, at a dinner party for around 250 people held in the Blosso Room of the Roosevelt Hotel in Hollywood, California.

1932

Hundreds died in fighting between Muslims and Hindus at Bombay.

1945

Prahraj Gopalchandra, modern author of Oria language, passed away.

1946

Gandhiji’s Cabinet Mission announced Plan.

1960

International Telex Service between India and U.K. introduced.

1968

In France, the May 1968 crisis escalated as a general strike spread to factories and industries across the country, shutting down newspaper distribution, air transport, and two major railroads. By the end of the month, millions of workers were on strike, and France seemed to be on the brink of radical leftist revolution.

1975

Via the southeast ridge route, Japanese mountaineer Junko Tabei became the first woman to reach the summit of Mt. Everest, the tallest mountain in the world.

1975

Sikkim High Court was established at Gangtok for Sikkim territory.

1975

Sikkim  was declared as the 22nd state of Indian Union.

1986

V. Shantaram, 75, was chosen for the Dada Saheb Phalke award.

1995

Government of India decides not to extend the validity of TADA Act.

1996

Atal Krishna Behari Vajpayee, leader of Bharatiya Janta Party, became the 10th Prime Minister for 13 days (from May 16, 1996 to May 28, 1996 [techinally till 01-06-1996]), although his ability to govern effectively was in doubt.

1998

India rejected China’s charges on N-tests.

1999

Senior Congress leaders opposed Sonia Gandhi as Prime Minister.

Related Articles:

Today in History – 15 May

Today in History – 14 May

Today in History -13 May

Today in History – 12 May

Classical Oscillators: Dynamics of Simple, Damped, and Driven Systems

0
classical oscillators

Table of Contents

  1. Introduction
  2. What Is an Oscillator?
  3. The Simple Harmonic Oscillator (SHO)
  4. Equation of Motion for SHO
  5. Energy in Simple Harmonic Motion
  6. Phase Space Representation
  7. Damped Harmonic Oscillator
  8. Driven Harmonic Oscillator
  9. Resonance and Phase Lag
  10. Nonlinear Oscillators (Overview)
  11. Applications of Classical Oscillators
  12. Transition to Quantum Oscillators
  13. Conclusion

1. Introduction

Oscillatory systems are central to physics, engineering, and nature. Whether itโ€™s a pendulum swinging, a mass on a spring, or the vibrations of atoms in a crystal, oscillations describe periodic motion fundamental to physical systems.

Classical oscillators are typically governed by Newtonโ€™s laws and offer an elegant example of how simple differential equations model physical reality. Understanding these systems builds the conceptual foundation for wave mechanics, circuit theory, molecular dynamics, and even quantum field theory.


2. What Is an Oscillator?

An oscillator is any system that exhibits periodic or quasi-periodic motion about an equilibrium point. The force driving the motion often arises from a restoring force, which increases with displacement from equilibrium and acts in the opposite direction.

Examples:

  • Mass-spring system
  • Simple pendulum (small angle)
  • LC electrical circuits
  • Vibrating strings

3. The Simple Harmonic Oscillator (SHO)

The simplest and most fundamental type of oscillator is the simple harmonic oscillator, where the restoring force is proportional to displacement:

\[
F = -kx
\]

Where:

  • k is the spring constant,
  • x is the displacement from equilibrium.

Using Newtonโ€™s second law \( F = ma \):

\[
m\ddot{x} + kx = 0
\]

This is the defining differential equation for SHO.


4. Equation of Motion for SHO

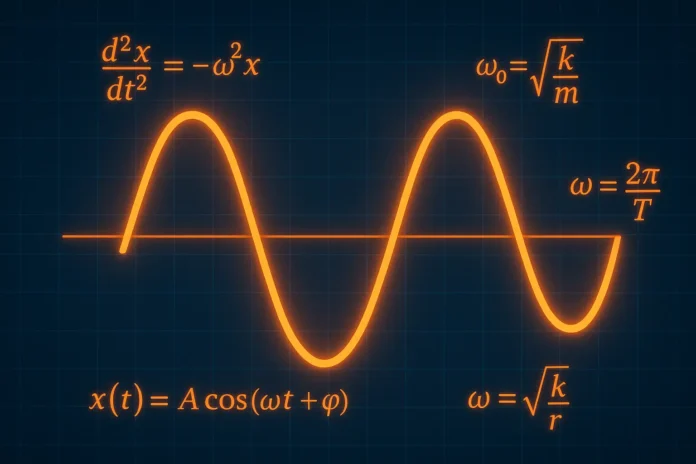
The general solution to the SHO differential equation:

\[
\ddot{x} + \omega^2 x = 0, \quad \text{where} \quad \omega = \sqrt{\frac{k}{m}}
\]

is given by:

\[
x(t) = A \cos(\omega t + \phi)
\]

Where:

  • A is the amplitude,
  • \(\phi\) is the phase constant,
  • \(\omega\) is the angular frequency.

Velocity and acceleration:

\[
v(t) = -A\omega \sin(\omega t + \phi)
\]
\[
a(t) = -A\omega^2 \cos(\omega t + \phi)
\]


5. Energy in Simple Harmonic Motion

The SHO conserves mechanical energy (no damping or driving forces). The total energy is the sum of kinetic and potential energies:

  • Kinetic Energy:
    \[
    K = \frac{1}{2}mv^2 = \frac{1}{2}mA^2 \omega^2 \sin^2(\omega t + \phi)
    \]
  • Potential Energy:
    \[
    U = \frac{1}{2}kx^2 = \frac{1}{2}kA^2 \cos^2(\omega t + \phi)
    \]
  • Total Energy:
    \[
    E = K + U = \frac{1}{2}kA^2 = \text{constant}
    \]

The energy oscillates between kinetic and potential forms.


6. Phase Space Representation

In phase space, SHO is represented as a circular or elliptical trajectory in the x – v plane.

\[
\left( \frac{x}{A} \right)^2 + \left( \frac{v}{A\omega} \right)^2 = 1
\]

This indicates conservation of energy and cyclical motion.


7. Damped Harmonic Oscillator

\[
m\ddot{x} + b\dot{x} + kx = 0
\]

Three regimes:

  1. Underdamped (/( b^2 < 4mk /)):
    \[
    x(t) = A e^{-\gamma t} \cos(\omega’ t + \phi)
    \]
    where \( \gamma = \frac{b}{2m}, \ \omega’ = \sqrt{\omega^2 – \gamma^2} \)
  2. Critically damped (\( b^2 = 4mk \))
  3. Overdamped (\( b^2 > 4mk \))

8. Driven Harmonic Oscillator

An external periodic force drives the system:

\[
m\ddot{x} + b\dot{x} + kx = F_0 \cos(\omega_d t)
\]

This leads to a steady-state solution where the system oscillates at the driving frequency ฯ‰d\omega_dฯ‰dโ€‹:

\[
x(t) = A(\omega_d) \cos(\omega_d t + \delta)
\]

Where:

\[
A(\omega_d) = \frac{F_0/m}{\sqrt{(\omega_0^2 – \omega_d^2)^2 + (2\gamma\omega_d)^2}}
\]

and ฮด\deltaฮด is the phase lag.


9. Resonance and Phase Lag

Resonance occurs when the driving frequency ฯ‰d\omega_dฯ‰dโ€‹ matches the natural frequency ฯ‰0\omega_0ฯ‰0โ€‹:

\[
\omega_d = \omega_0 = \sqrt{\frac{k}{m}}
\]

At resonance, the amplitude is maximized (especially in low damping):

\[
A_{\text{res}} = \frac{F_0}{b\omega_0}
\]

Phase lag:

  • Below resonance: oscillator lags driver
  • At resonance: phase difference = ฯ€2\frac{\pi}{2}2ฯ€โ€‹
  • Above resonance: oscillator leads driver

10. Nonlinear Oscillators (Overview)

When the restoring force is not proportional to displacement, the system becomes nonlinear.

Example: Duffing oscillator

\[
m\ddot{x} + b\dot{x} + kx + \beta x^3 = 0
\]

Nonlinear oscillators can exhibit:

  • Amplitude-dependent frequencies,
  • Bifurcations,
  • Chaos under certain conditions.

These systems are harder to solve analytically and are typically explored using numerical methods.


11. Applications of Classical Oscillators

Oscillatory systems appear in nearly every branch of science:

  • Mechanics: Springs, pendulums, suspension systems.
  • Electronics: LC and RLC circuits follow similar differential equations.
  • Engineering: Resonance in bridges, damping in building structures.
  • Biology: Heartbeats, circadian rhythms.
  • Optics: Light interference and cavity oscillations.
  • Acoustics: Sound wave production and propagation.

12. Transition to Quantum Oscillators

The quantum harmonic oscillator is one of the few analytically solvable systems in quantum mechanics.

It replaces Newtonโ€™s second law with the Schrรถdinger equation:

\[
-\frac{\hbar^2}{2m} \frac{d^2 \psi}{dx^2} + \frac{1}{2}kx^2 \psi = E \psi
\]

The solutions yield quantized energy levels:

\[
E_n = \left( n + \frac{1}{2} \right)\hbar \omega
\]

No classical oscillator has a non-zero ground-state energy โ€” a key difference with quantum behavior.


13. Conclusion

Classical oscillators, especially the simple harmonic oscillator, serve as idealized systems for understanding periodic motion. Their mathematical tractability and wide applicability make them essential for studying more complex phenomena such as wave propagation, resonance, and quantum transitions.

From the swing of a pendulum to electron behavior in atoms, oscillators represent one of physics’ most universal and unifying models.

.
Today in History – 15 May

0
Today in History 15 May

Today in History 15 May

1729

Khanderao Dabhade, great warrior in Maratha kingdom, passed away.

1756

The Seven Years War, a global conflict known in America as the French and Indian War, officially begins when England declares war on France. However, fighting and skirmishes between England and France had been going on in North America for years.

1817

Maharshi Devendranath Tagore, Bengali social reformer and father of Rabindranath Tagore, was born.

1864

Mahavirprasad Dvivedi, famous Hindi litterateur, poet, writer and editor, was born at Daulatpur village in UP.

1873

The proposal to dissolve East India Company was passed in England.

1878

Sivnath Shastri and Ananda Mohan Bose, under the leadership of the younger group of Brahmo Sama, rebelled and started Sadharan Brahmo Samaj.

1937

On this day in 1937, Madeleine Albright, Americaโ€™s first female secretary of state, is born Maria Jana Korbelova in Prague, Czechoslovakia (now the Czech Republic).

1941

On May 15, 1941, the jet-propelled Gloster-Whittle E 28/39 aircraft flies successfully over Cranwell, England, in the first test of an Allied aircraft using jet propulsion. The aircraftโ€™s turbojet engine, which produced a powerful thrust of hot air, was devised by Frank Whittle, an English aviation engineer and pilot generally regarded as the father of the jet engine.

1942

On this day in 1942, gasoline rationing began in 17 Eastern states as an attempt to help the American war effort during World War II. By the end of the year, President Franklin D. Roosevelt had ensured that mandatory gasoline rationing was in effect in all 50 states.

1949

Matsya Union formally merged with Greater Rajasthan.

1958

Gift Tax Act was introduced.

1963

On May 15, 1963, Gordon Cooper is launched into space aboard Faith 7 on the longest American space mission to that date. Faith 7 was the capstone of Project Mercury, the NASA program that put the first American into space in 1961 and the first astronaut into orbit in 1962. Cooper completed 22 orbits of the earth and spent 34 hours in space. He was the first American astronaut to spend more than a day in space. On the afternoon of May 16, Faith 7 landed safely in the Pacific Ocean, four miles from the recovery ship Kearsarge.

1989

NAL’s 0.6 m transonic wind tunnel is commissioned. Total project cost is about Rs 20 million.

1992

BSE closed.

1993

K.M. Cariappa, field marshal and Major General, passed away at the age of 93.

1996

The 11th Lok Sabha constituted as Election Commission submits a list of 534 successful candidates to President.

1997

Yaseen Malik, All-Party Hurriyat Conference leader, was released from Tihar jail.

1998

Pandit Ravi Shankar, Sitar maestro, receives the 1998 Polar music award.

1999

The BJP and at least 13 of its allies rename themselves the National Democratic Alliance.

Related Articles:

Today in History – 14 May

Today in History -13 May

Today in History – 12 May

Today in History – 11 May